COVERT MULTI-SPECTRAL MARITIME RECONNAISSANCE
SIMPLR-AUV
Covert. Multi-Spectral. Autonomous.
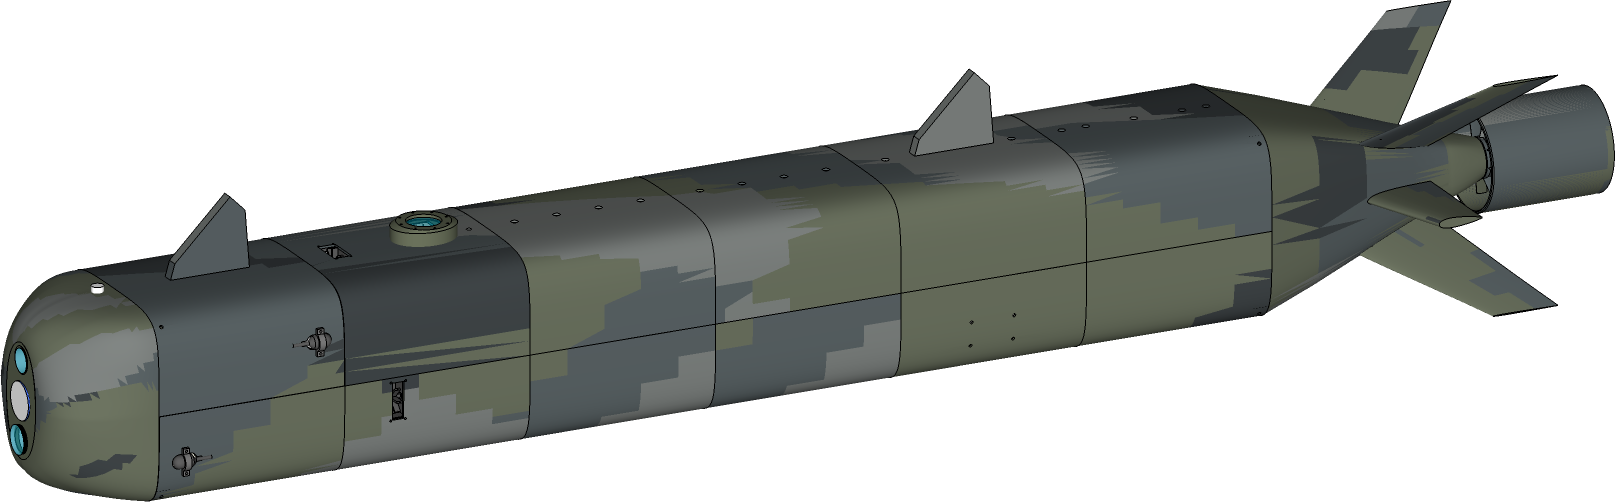
A small autonomous underwater vehicle that swims the objective and collects the adversary's RF, acoustic, and visual picture — then brings it home. Silent the whole time, operators never exposed. Built on a modular, software-defined platform with deterministic mission orchestration and pre-deployment simulation.
A COMPLETE AUTONOMOUS MISSION SYSTEM
Mission Intent to Underwater Impact
Cognitive Vehicles integrates mission planning, vehicle configuration, simulation, autonomous execution, and post-mission analysis into one coherent system. SIMPLR-AUV is the first vehicle architecture built around that approach.
01PlanDefine mission objectives and geometry
→
02ConfigureCOMPILR selects a feasible configuration
→
03ValidateExercise the actual autonomy stack in simulation
→
04DeployExecute with SIMPLR-AUV
→
05AdaptGIZMO orchestrates mission behavior
→
06AnalyzeTurn mission data into engineering evidence
THE SIMPLR-AUV PLATFORM
Modular. Capable. Built for the Mission.
SIMPLR-AUV uses a free-flooding outer hull around two watertight electronics cylinders with a wet-mounted, pressure-tolerant energy module. The architecture separates mission sensing, vehicle management, payloads, and energy while preserving common power, network, and mechanical interfaces.
- Two-WTC vehicle architecture
- Wet-mounted pressure-tolerant energy module
- Interchangeable mission payload interfaces
- Designed for rapid reconfiguration
- Low-complexity, software-defined capability
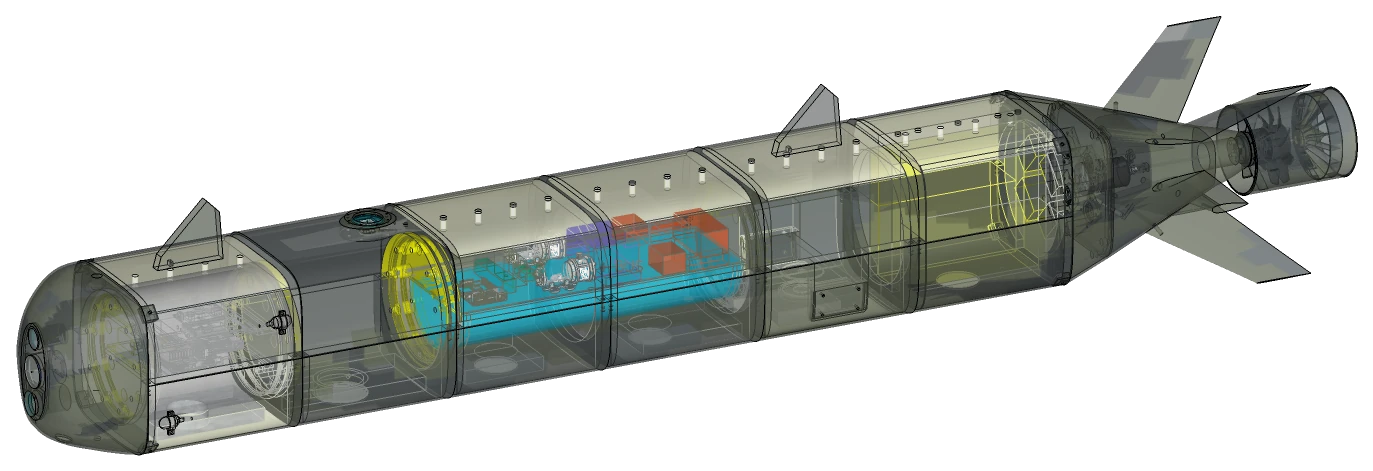
~85 inLength
~8 inDiameter
60 mDesign depth
24+ hEndurance target
0.6–2.0 m/sSpeed range
THE FLAGSHIP MISSION
Find, then fix — with no one in the threat ring.
SIMPLR-AUV conducts covert maritime reconnaissance across three modalities at once. It surveys an objective wide and silent to find every contact of interest, the operator designates the ones that matter, and the vehicle returns to collect them in full for exploitation — all from an unmanned platform, with the crew kept well outside the objective.
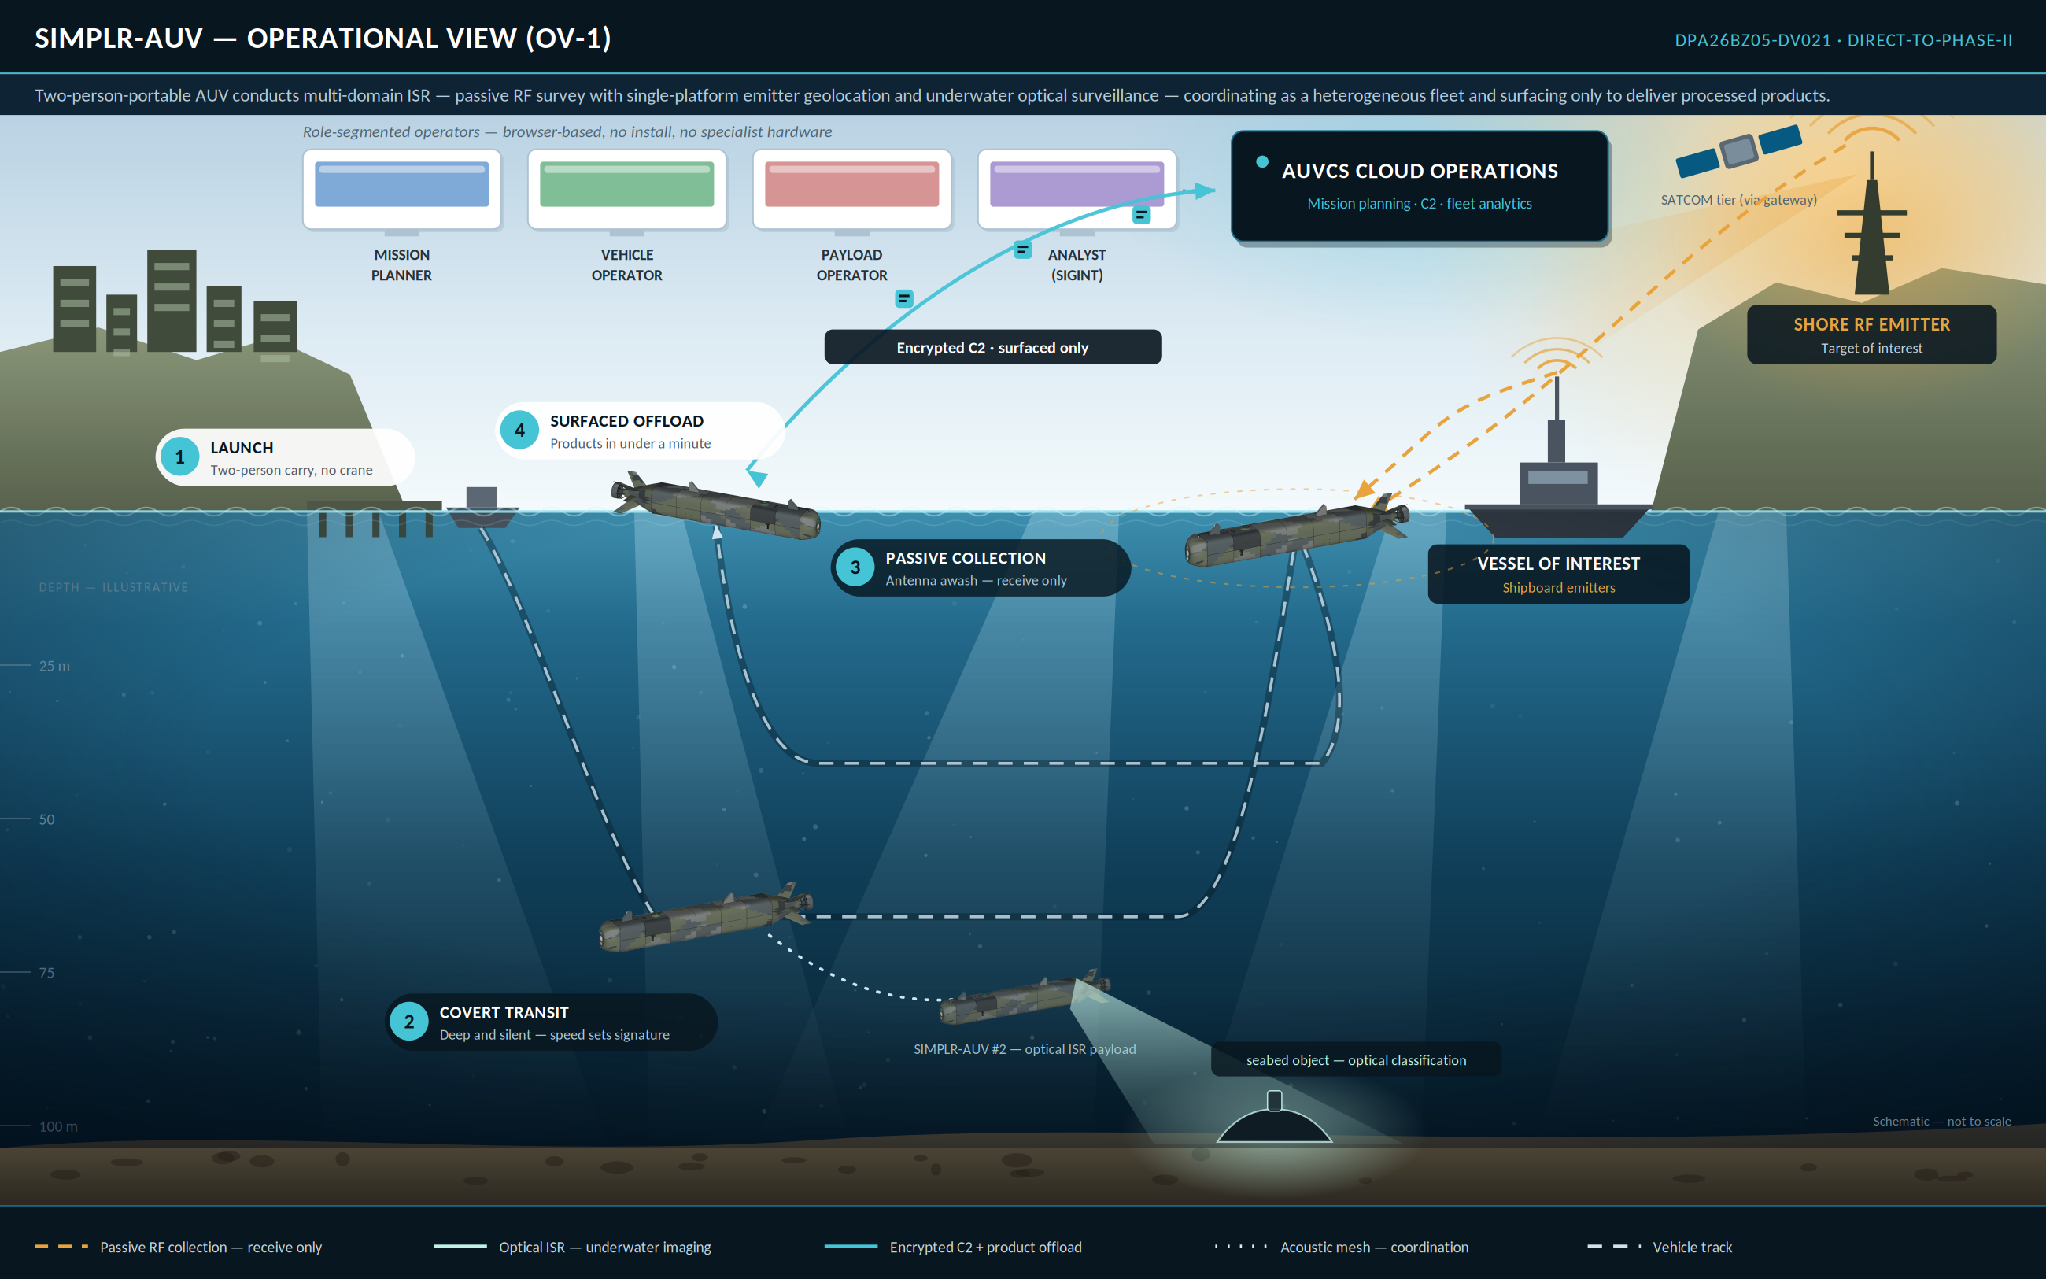
Passive RF Survey
Detect, identify, and geolocate emitters from a single platform — receive-only, antenna awash. Communications nets mapped; nothing radiated during collection.
Acoustic Signatures
A rapidly reconfigurable payload module passively profiles machinery and propulsion noise — including the low-signature semi-submersibles and narco-submarines that evade other sensors.
Underwater Video
Optical classification of hulls and seabed objects at close range, delivering visual confirmation to pair with the RF and acoustic picture.
Deniable emplacementDormant until taskedZero emissions on surveyOperator-designated targetsExfil over WiFi / LTE
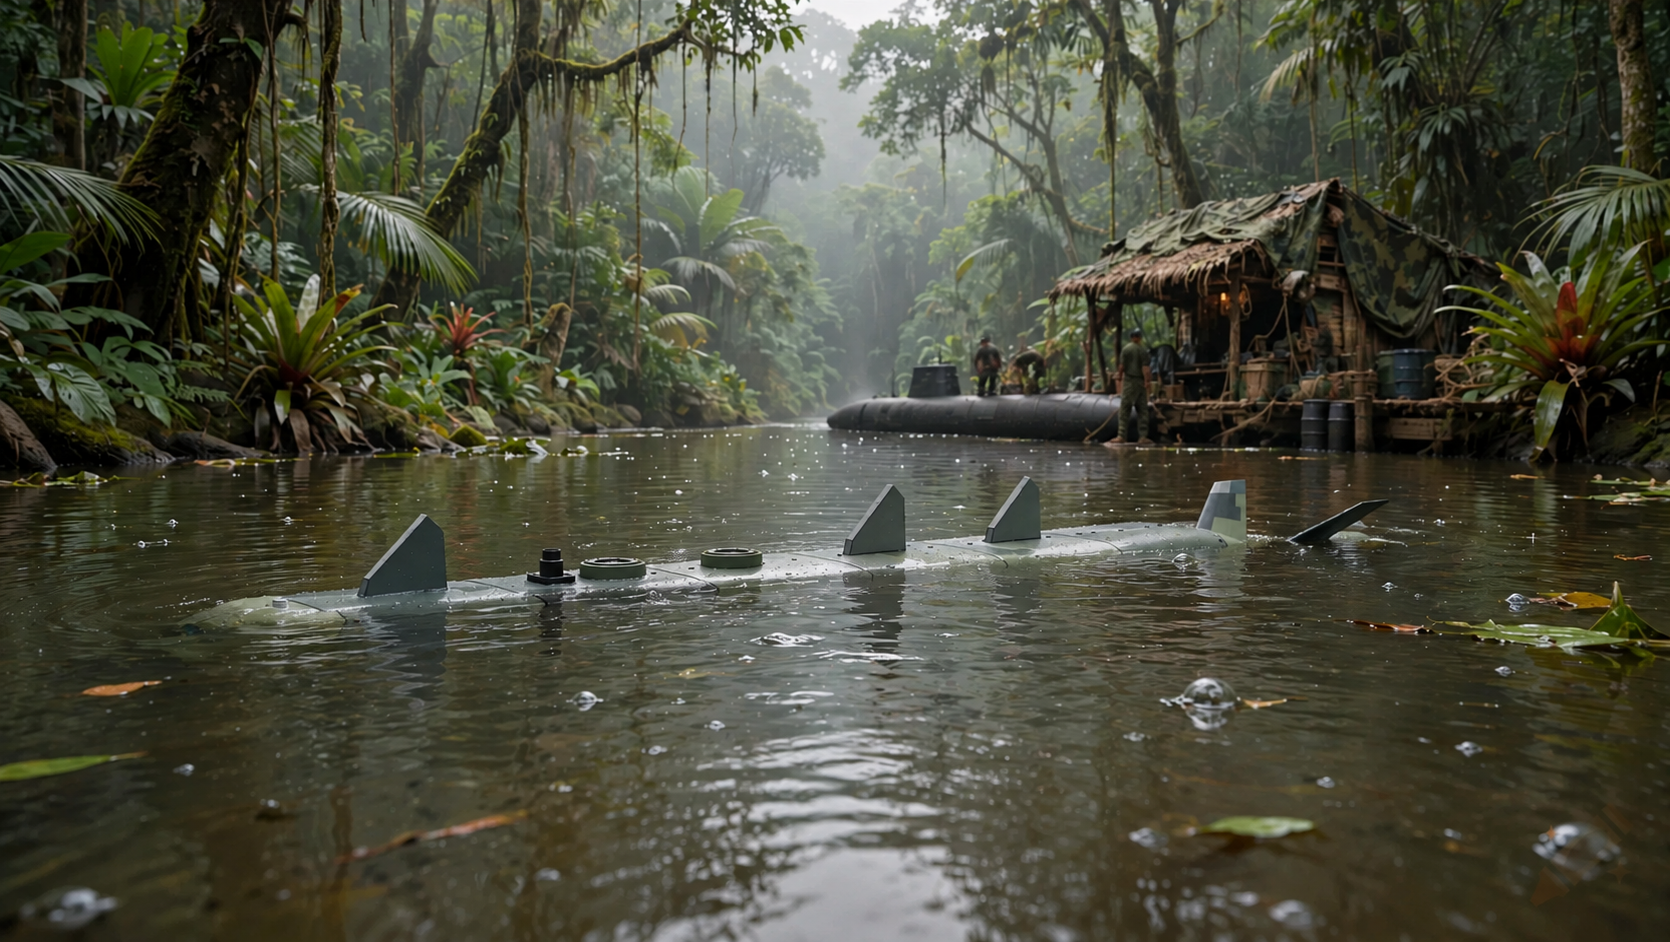
8 / 8Emitters located
0Emissions on survey
4 / 4Targets collected
3Collection modalities
1Sortie, find to fix
GIZMO MISSION ORCHESTRATION
Mission intent becomes adaptive behavior.
GIZMO evaluates mission objectives, operating zones, vehicle state, observations, and available capabilities to determine what the vehicle should do next. Its mission logic is deterministic, auditable, and subordinate to independent vehicle-safety functions.
DeterministicExplainableBoundedReplayable
COMPILR CONFIGURATION COMPILER
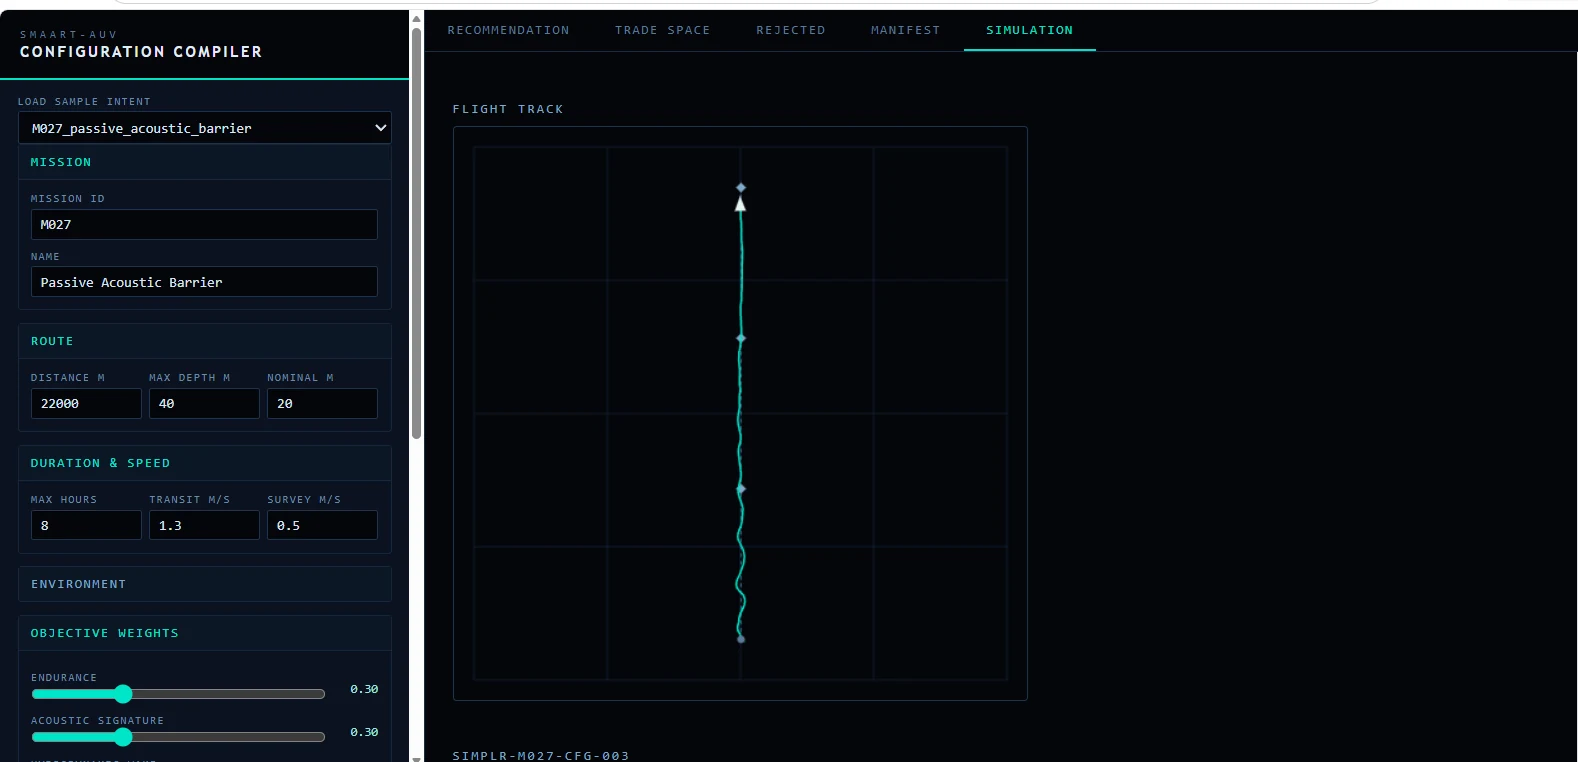
Mission intent becomes a validated vehicle definition.
COMPILR evaluates mission objectives and hard constraints, screens candidate configurations, solves mass and trim properties, ranks feasible options, and validates the selected configuration through the same simulation environment used by the autonomy stack.
The public site describes COMPILR's function and engineering role without exposing its internal scoring, implementation details, or private source.
MISSION SYSTEMS IN ACTION
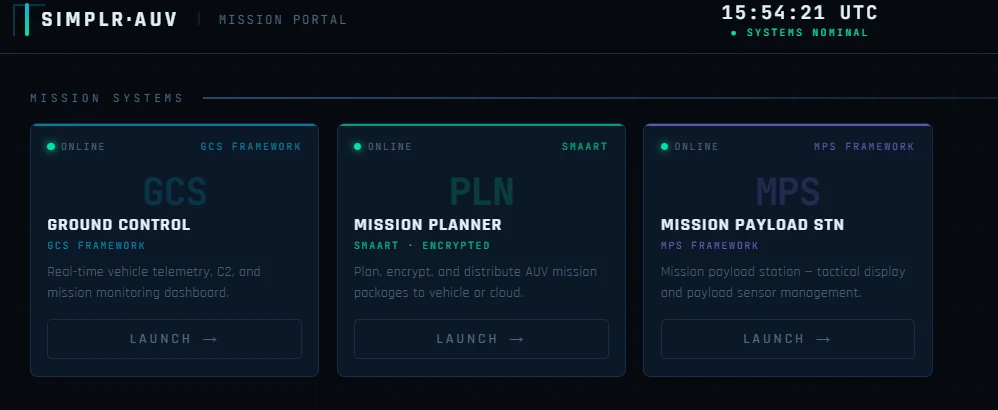
One environment from planning through analysis.
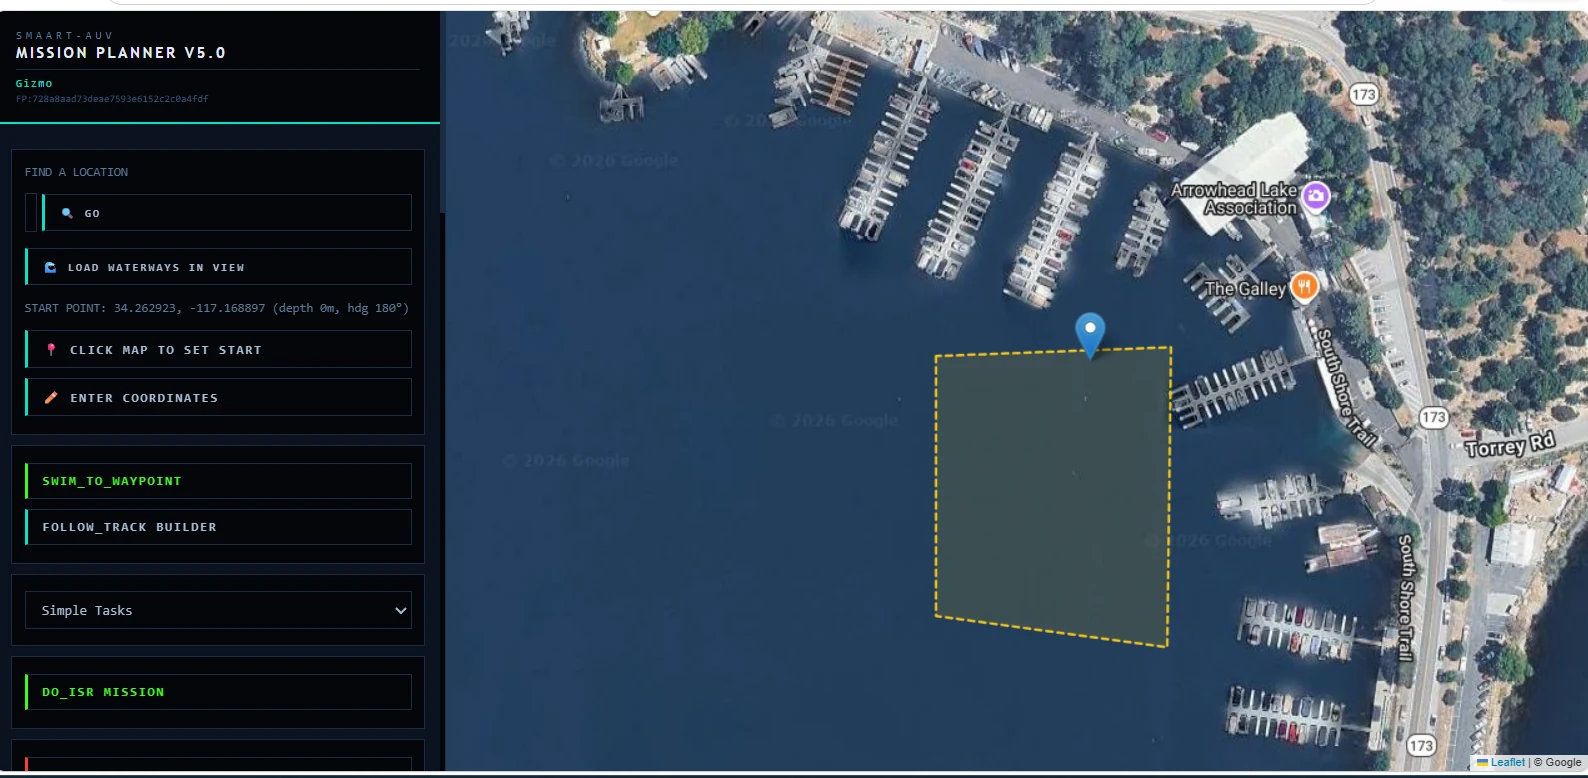
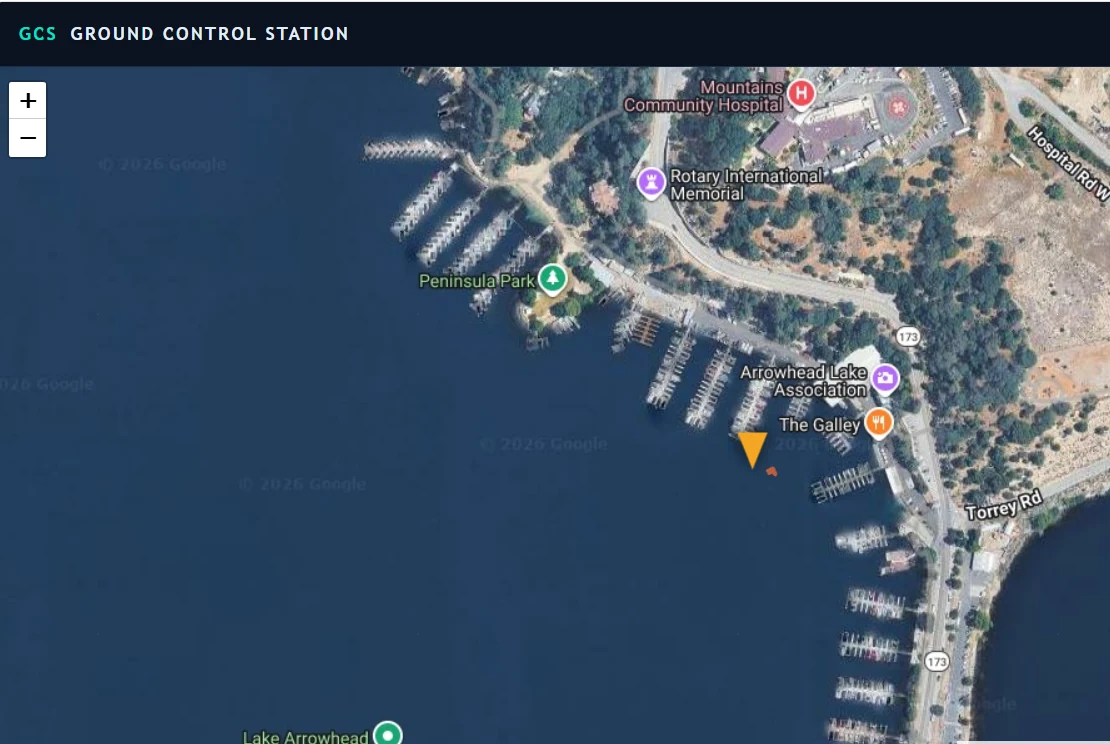
The operator-facing suite is browser delivered, role segmented, and built around the same mission vocabulary used by the vehicle.
OPEN SYSTEMS ENGINEERING
Capability should be replaceable without rebuilding the vehicle.
SIMPLR separates mission orchestration, guidance, navigation and control, hardware abstraction, payload services, and cloud operations so each layer can evolve independently.
Mission Layer
Objectives, operating zones, policy, and GIZMO orchestration.
Behavior Layer
Guidance plugins and mission tasks with bounded completion logic.
Vehicle Layer
Navigation, control, obstacle avoidance, and independent safety functions.
Platform Layer
Hardware abstraction, vehicle sensors, actuators, and common interfaces.
Payload Layer
Interchangeable RF, acoustic, optical, environmental, and future mission payloads — re-roled by module swap in under a day.
Simulation Layer
The production autonomy stack runs against simulation or physical hardware through the same abstraction boundary.
DEVELOPMENT STATUS
Software-first, evidence-driven development.
The autonomy stack, GIZMO, browser mission environment, and configuration tooling are being developed and exercised through simulation and hardware-in-the-loop workflows. Prototype vehicle hardware is in development; vehicle-level performance claims remain targets until controlled physical testing is complete.
ABOUT COGNITIVE VEHICLES
Autonomous systems built around mission reasoning.
Cognitive Vehicles LLC develops autonomous vehicle architectures, mission software, modular payload integration, simulation, and undersea robotic systems. SIMPLR-AUV is the company's principal development platform for mission-defined autonomy and rapidly reconfigurable underwater capability.
A MORE KNOWLEDGEABLE OCEAN
Build the next mission capability.
For research, integration, teaming, and program inquiries, contact Cognitive Vehicles LLC.
wayne@simplr-auv.comWayne Folsom · Founder & CEO
wayne@simplr-auv.com · (949) 436-8704